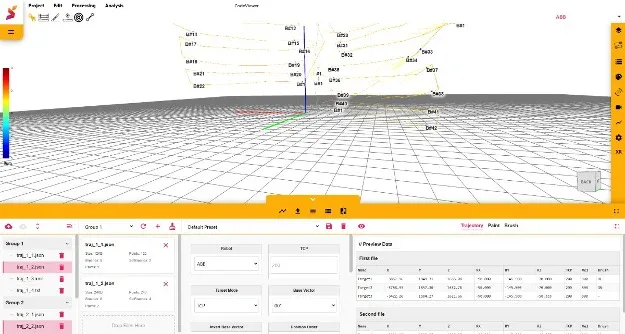
A newly built system for importing and exporting trajectories that significantly simplifies project creation — with trajectory preview before import, reusable templates, and support across all robotic systems.
Multi-language support
ABB RAPID, Yaskawa, Fanuc, and others – work efficiently across robot platforms.
Clear visualization
Motion instructions are structured together with system instruction for easier reading, review, and debugging.
Import & export
Simplifies integration, cuts manual rework, speeds up deployment and optimization.
Greater transparency, flexibility, and productivity in robot programming part.
For more insights, follow us on LinkedIn.